Last Update: 2003/June/24
Last Update: 2003/June/24
| What's ADS? | ||||||||||||||||||||||
| Attitude Determination
Subsystem conducts analyses of a direction and a motion of CUTE-I on orbit.Various
missions, such as an astronomical observation, a meteorological observation
and a satellite communication, are required the following functions: - One function determines a satellite's attitude using sensors ( = Attitude Determination) . - Another function stabilizes and orients a satellite in desired directions using actuator ( = Attitude Control ). In this project, we aim at acquiring the attitude determination techniques of CUTE-I. |
||||||||||||||||||||||
| Objectives | ||||||||||||||||||||||
| The subsystem develops
the following issues to measure motions of CUTE-I on orbit. - Selection of attitude determination sensors - Circuit design - Environment test (thermal-vacuum test, vibration test, and so on) - Sensor calibration - Operation and analysis The system measures and estimates the motion and attitude of CUTE-I through the development. |
||||||||||||||||||||||
| Sensor Configuration | ||||||||||||||||||||||
| CUTE-I has three kinds of sensors for determining the attitude. | ||||||||||||||||||||||
 Piezoelectric Vibrating Gyroscope |
||||||||||||||||||||||
| The sensors measure angular velocity vector of CUTE-I. CUTE-I has four gyroscope for redundancy. The following table indicates the specification of gyroscope. | ||||||||||||||||||||||
|
||||||||||||||||||||||
 Dual Axis Accelerometer |
||||||||||||||||||||||
| The accelerometers measure the centrifugal acceleration generated by rotation of CUTE-I. This data is used for comparing with the gyroscope's data. There are also four accelerometers for redundancy.The following table indicates the specification of accelerometer. | ||||||||||||||||||||||
|
||||||||||||||||||||||
 CMOS Sun sensor (LSS Original) |
||||||||||||||||||||||
| The subsystem developed
LSS original sun sensor using commercial CMOS camera. The sun sensor takes a picture of sun and calculates a pixel-based position of sun light on CMOS image. The sensor outputs the position data and other support data to On-Board Computer of CUTE-I. CUTE-I cannot transmit the image taken by CMOS Camera. We will describe the sun sensor more detail in sun sensor description page (under construction). |
||||||||||||||||||||||
| Sensor Circuit | ||||||||||||||||||||||
| The subsystem designed and made three kinds of circuit boards. The boards are indicated by the following images. | ||||||||||||||||||||||
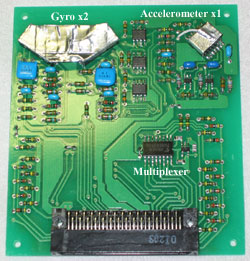
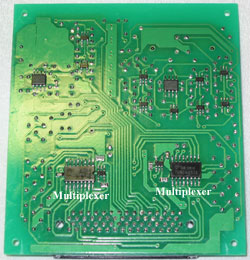
 Sensor Board 1 (W80mm×L90mm×t10mm) |
||||||||||||||||||||||
| Sensor Board 1 has two gyroscopes and one dual axis accelerometer. Moreover the board has three multiplexers because it is in charge of a data relay station for thermistors which attaches various places into CUTE-I and current/voltage data of EPS. | ||||||||||||||||||||||
|
||||||||||||||||||||||
|
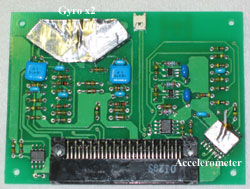
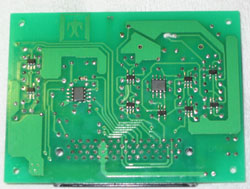
Sensor Board 2 (W80mm×L60mm×t10mm) |
||||||||||||||||||||||
| Sensor Board 2 consists of only two gyroscopes and one dual axis accelerometer. | ||||||||||||||||||||||
|
||||||||||||||||||||||
|
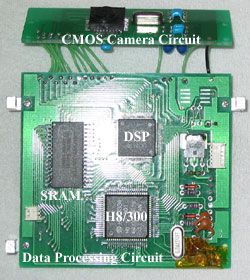
Sun Sensor Board (W70mm×L100mm×t10mm) |
||||||||||||||||||||||
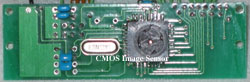
| Sun sensor is divided
into CMOS camera board and data processing board. On CMOS camera board,
there is CMOS image sensor which takes a picture. The data processing circuit
calculates a pixel-based position of sun light on CMOS image taken by CMOS
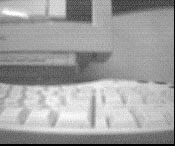
image sensor and outputs the calculation results. The following picture indicates a monochrome taken the CMOS camera. This picture shows a desktop PC. |
||||||||||||||||||||||
|
||||||||||||||||||||||
|
||||||||||||||||||||||
| Attitude Determination Method | ||||||||||||||||||||||
| We will explain a method of attitude determination of CUTE-I (under construction). | ||||||||||||||||||||||
| Development History | ||||||||||||||||||||||
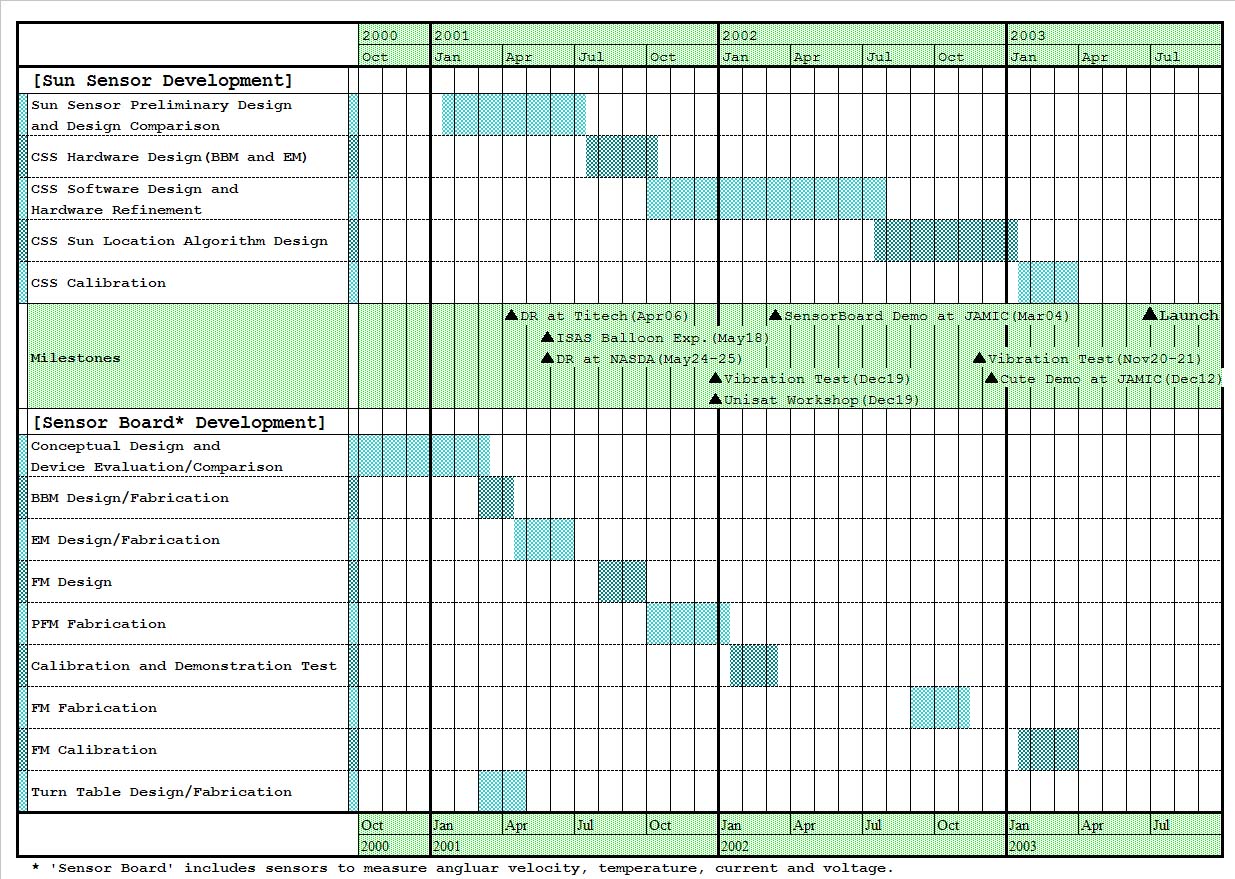
| The following picture shows out development history. The system has developed since 4th quarter of 2000 and complete to develop FM board at the beginning of 2003. We transported the FM board to Russia in order to launch by Russian Rocket and are waiting for launch. | ||||||||||||||||||||||
 |
||||||||||||||||||||||
| Future Plan | ||||||||||||||||||||||
| Future plan of the subsystem are the sophistication of the attitude determination technology and the development of attitude control technology based on experiences in the project. | ||||||||||||||||||||||


|
||||||||||||||||||||||
|